

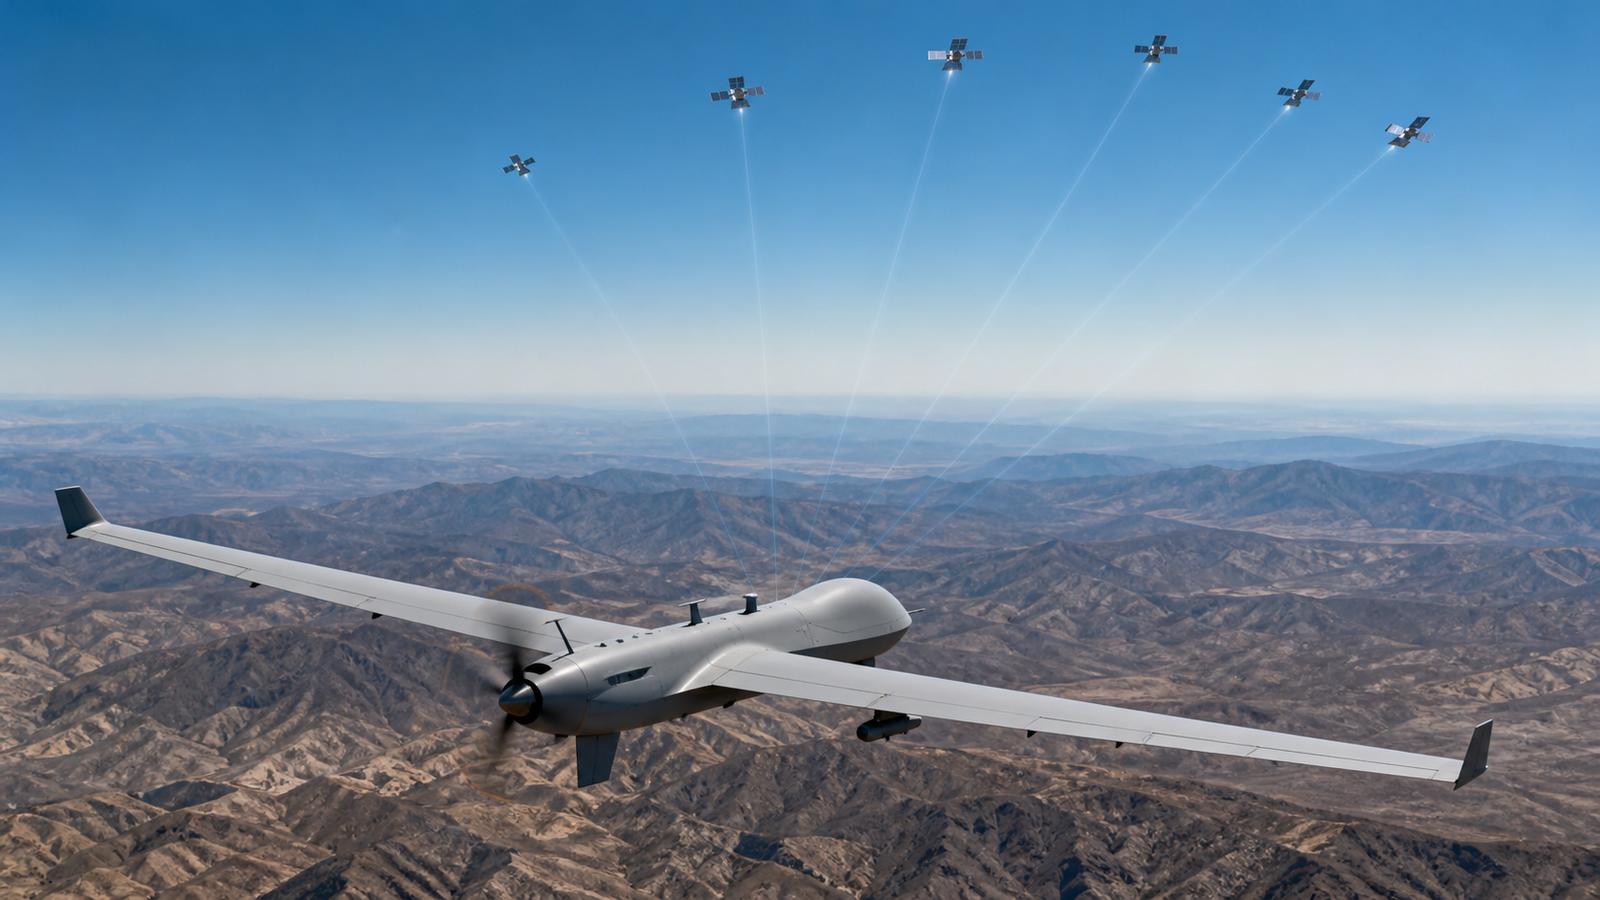
UAV Navigation is involved in developing a navigation system for unmanned aircraft that will use signals from low Earth orbit (LEO) communications satellites as an alternative when global navigation satellite systems (GNSS), including GPS, are degraded, denied, jammed, or spoofed.
The research is part of the European Space Agency’s (ESA) Navisp Element 2 program, which is funding the project. The consortium is led by Inster–Grupo Oesía and includes UAV Navigation, the Telecommunications Technology Center of Catalonia (CTTC), and Sicwave.
Communications signals for position estimation
The system will leverage non-cooperative signals—that is, transmissions not designed to provide positioning or navigation services. In this case, they will come from LEO constellations, particularly in the Ka band, and will be used to obtain position, navigation, and timing data that complement conventional sources.
UAV Navigation will integrate this data into its drone autopilot. Under the project’s approach, algorithms will combine information derived from LEO signals with inertial measurements, air data, GNSS when available, and vision-based navigation. The stated goal is to maintain an estimate of the aircraft’s position and state in scenarios without reliable GNSS access.
The project will also examine the generation of position estimates using electronically steered multibeam antennas and their integration into the drone’s navigation filter. Its backers argue that the antennas’ high directivity may improve resilience to interference and signal spoofing compared with omnidirectional GNSS antennas.
The solution is aimed at unmanned aerial systems operating beyond visual line of sight or in contested airspace, with potential applications in defense, security, intelligence, surveillance, and reconnaissance. The consortium plans to validate the approach in a representative flight environment, although the available information does not specify a testing timetable.